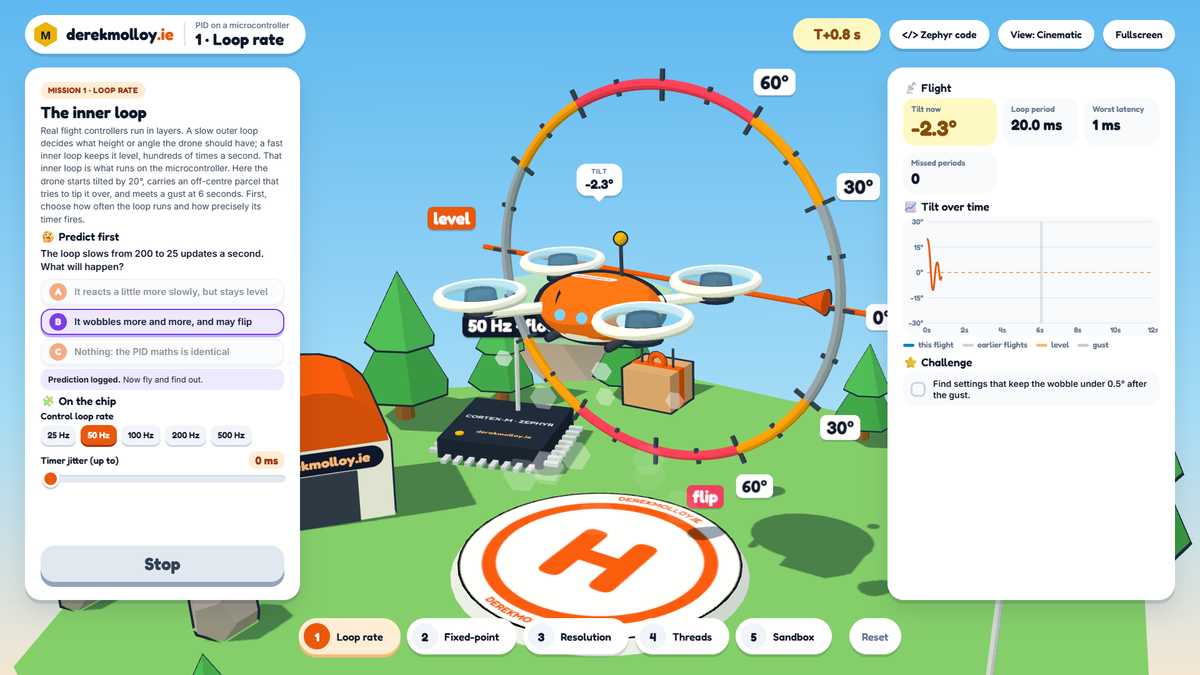
PID on a Microcontroller: Making Timing Visible in a 3D Game
Topics
A follow-on to PID Flight School. The drone's roll loop runs on a simulated Cortex-M under Zephyr, so students can see what loop rate, fixed-point maths, sensor resolution and thread priorities do to a controller.
Visit derekmolloy.ie ↗ (opens in new tab)Found via Kagi Small Web (opens in new tab)